Homepage prototype
Two narrative directionsFlight shown as storyboard frames

Energy
for movement.

A passenger drone. One mission for three RAKTON DRIVE technologies.

Explore the platform inside

Flight begins with the coordinated work of a motor, a controller and a battery.

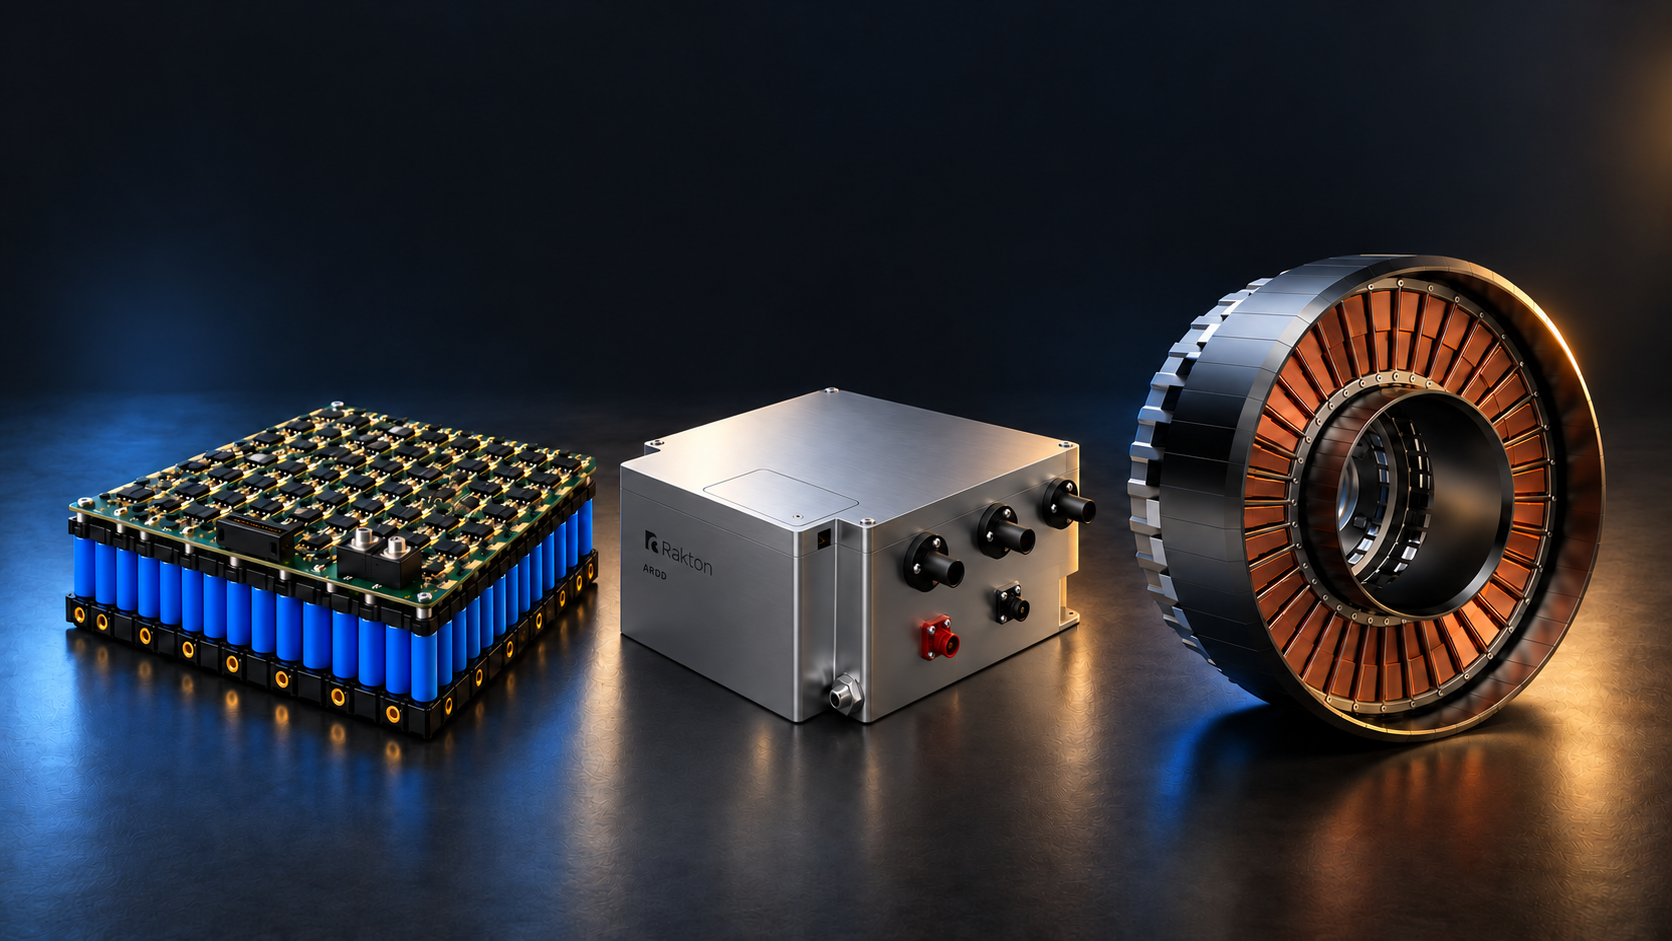
RBT battery, ARDD controller, OW-RFMMC motor

Three technologies.
One platform.

Inside the aircraft.
A complete platform.

Electric drive, control and power — built around your product.

From the aircraft’s movement to the technologies that make it possible.

OW-RFMMC motor, ARDD controller and RBT battery. A complete platform, individual components or technology licensing.

Discuss a project

Each component.
A shared result.

Explore the technologies individually — then see how they work together.

OW-RFMMC
OW-RFMMC

Torque.
Mass. Dimensions.

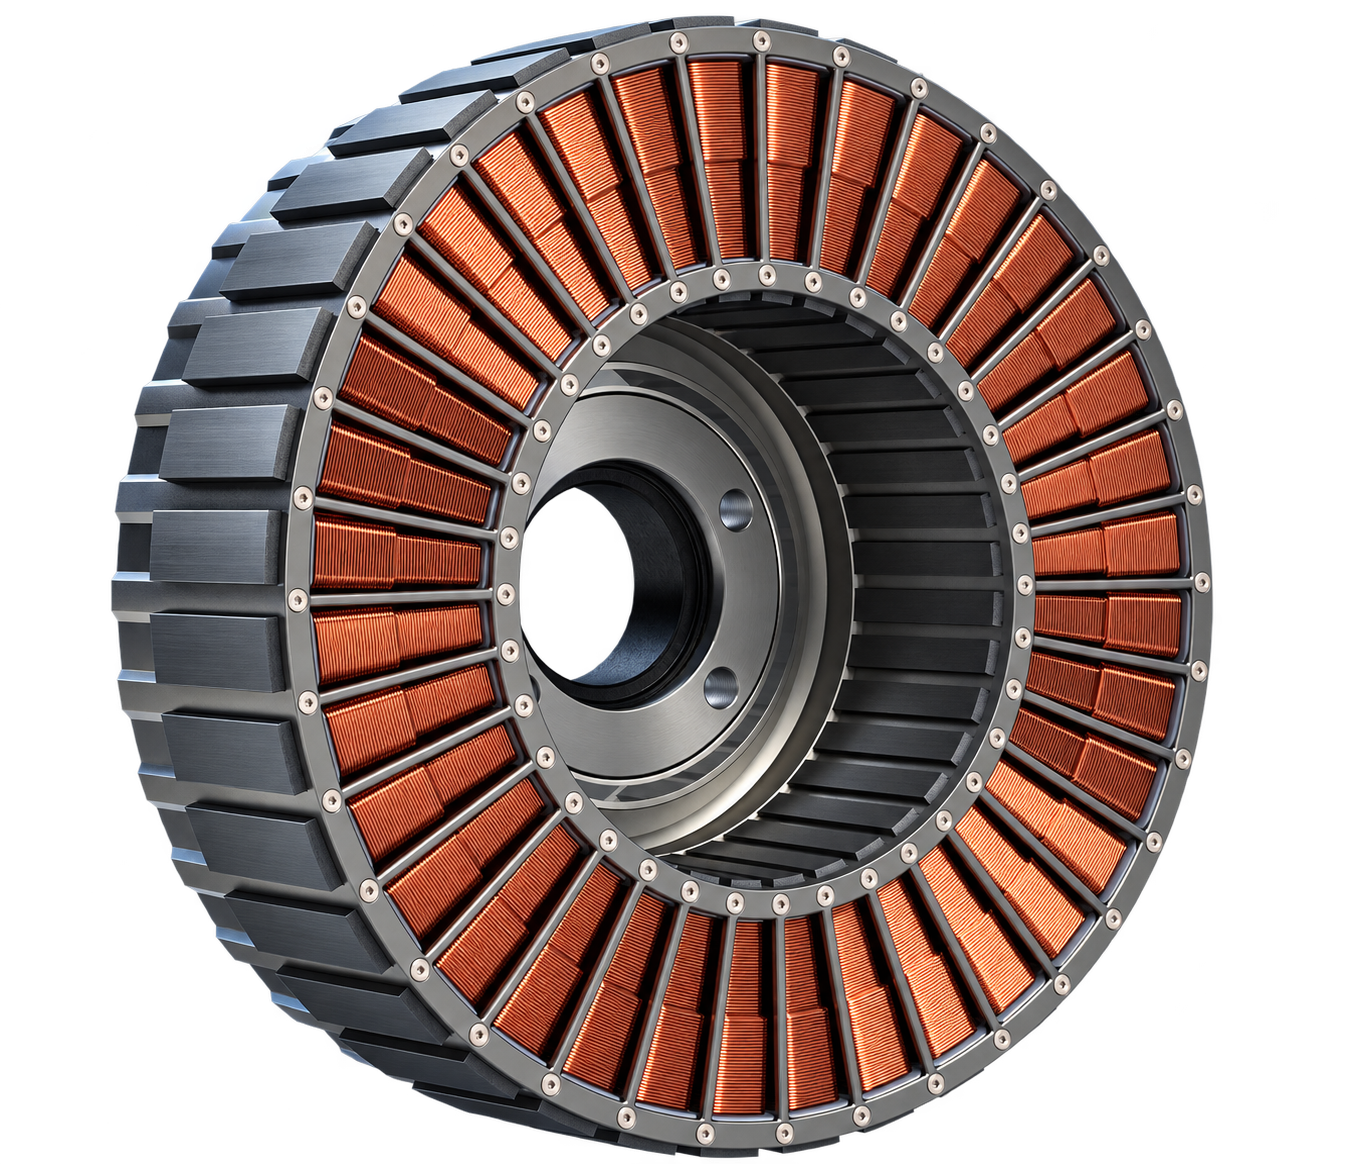
An open-winding motor. High torque and specific performance for products in which every kilogram matters.

Open windings

Individual phase control in coordination with the platform controller.

Segmented structure

The motor architecture is revealed through its individual working elements.

For your product: a motor matched to torque, power, mass and packaging requirements.
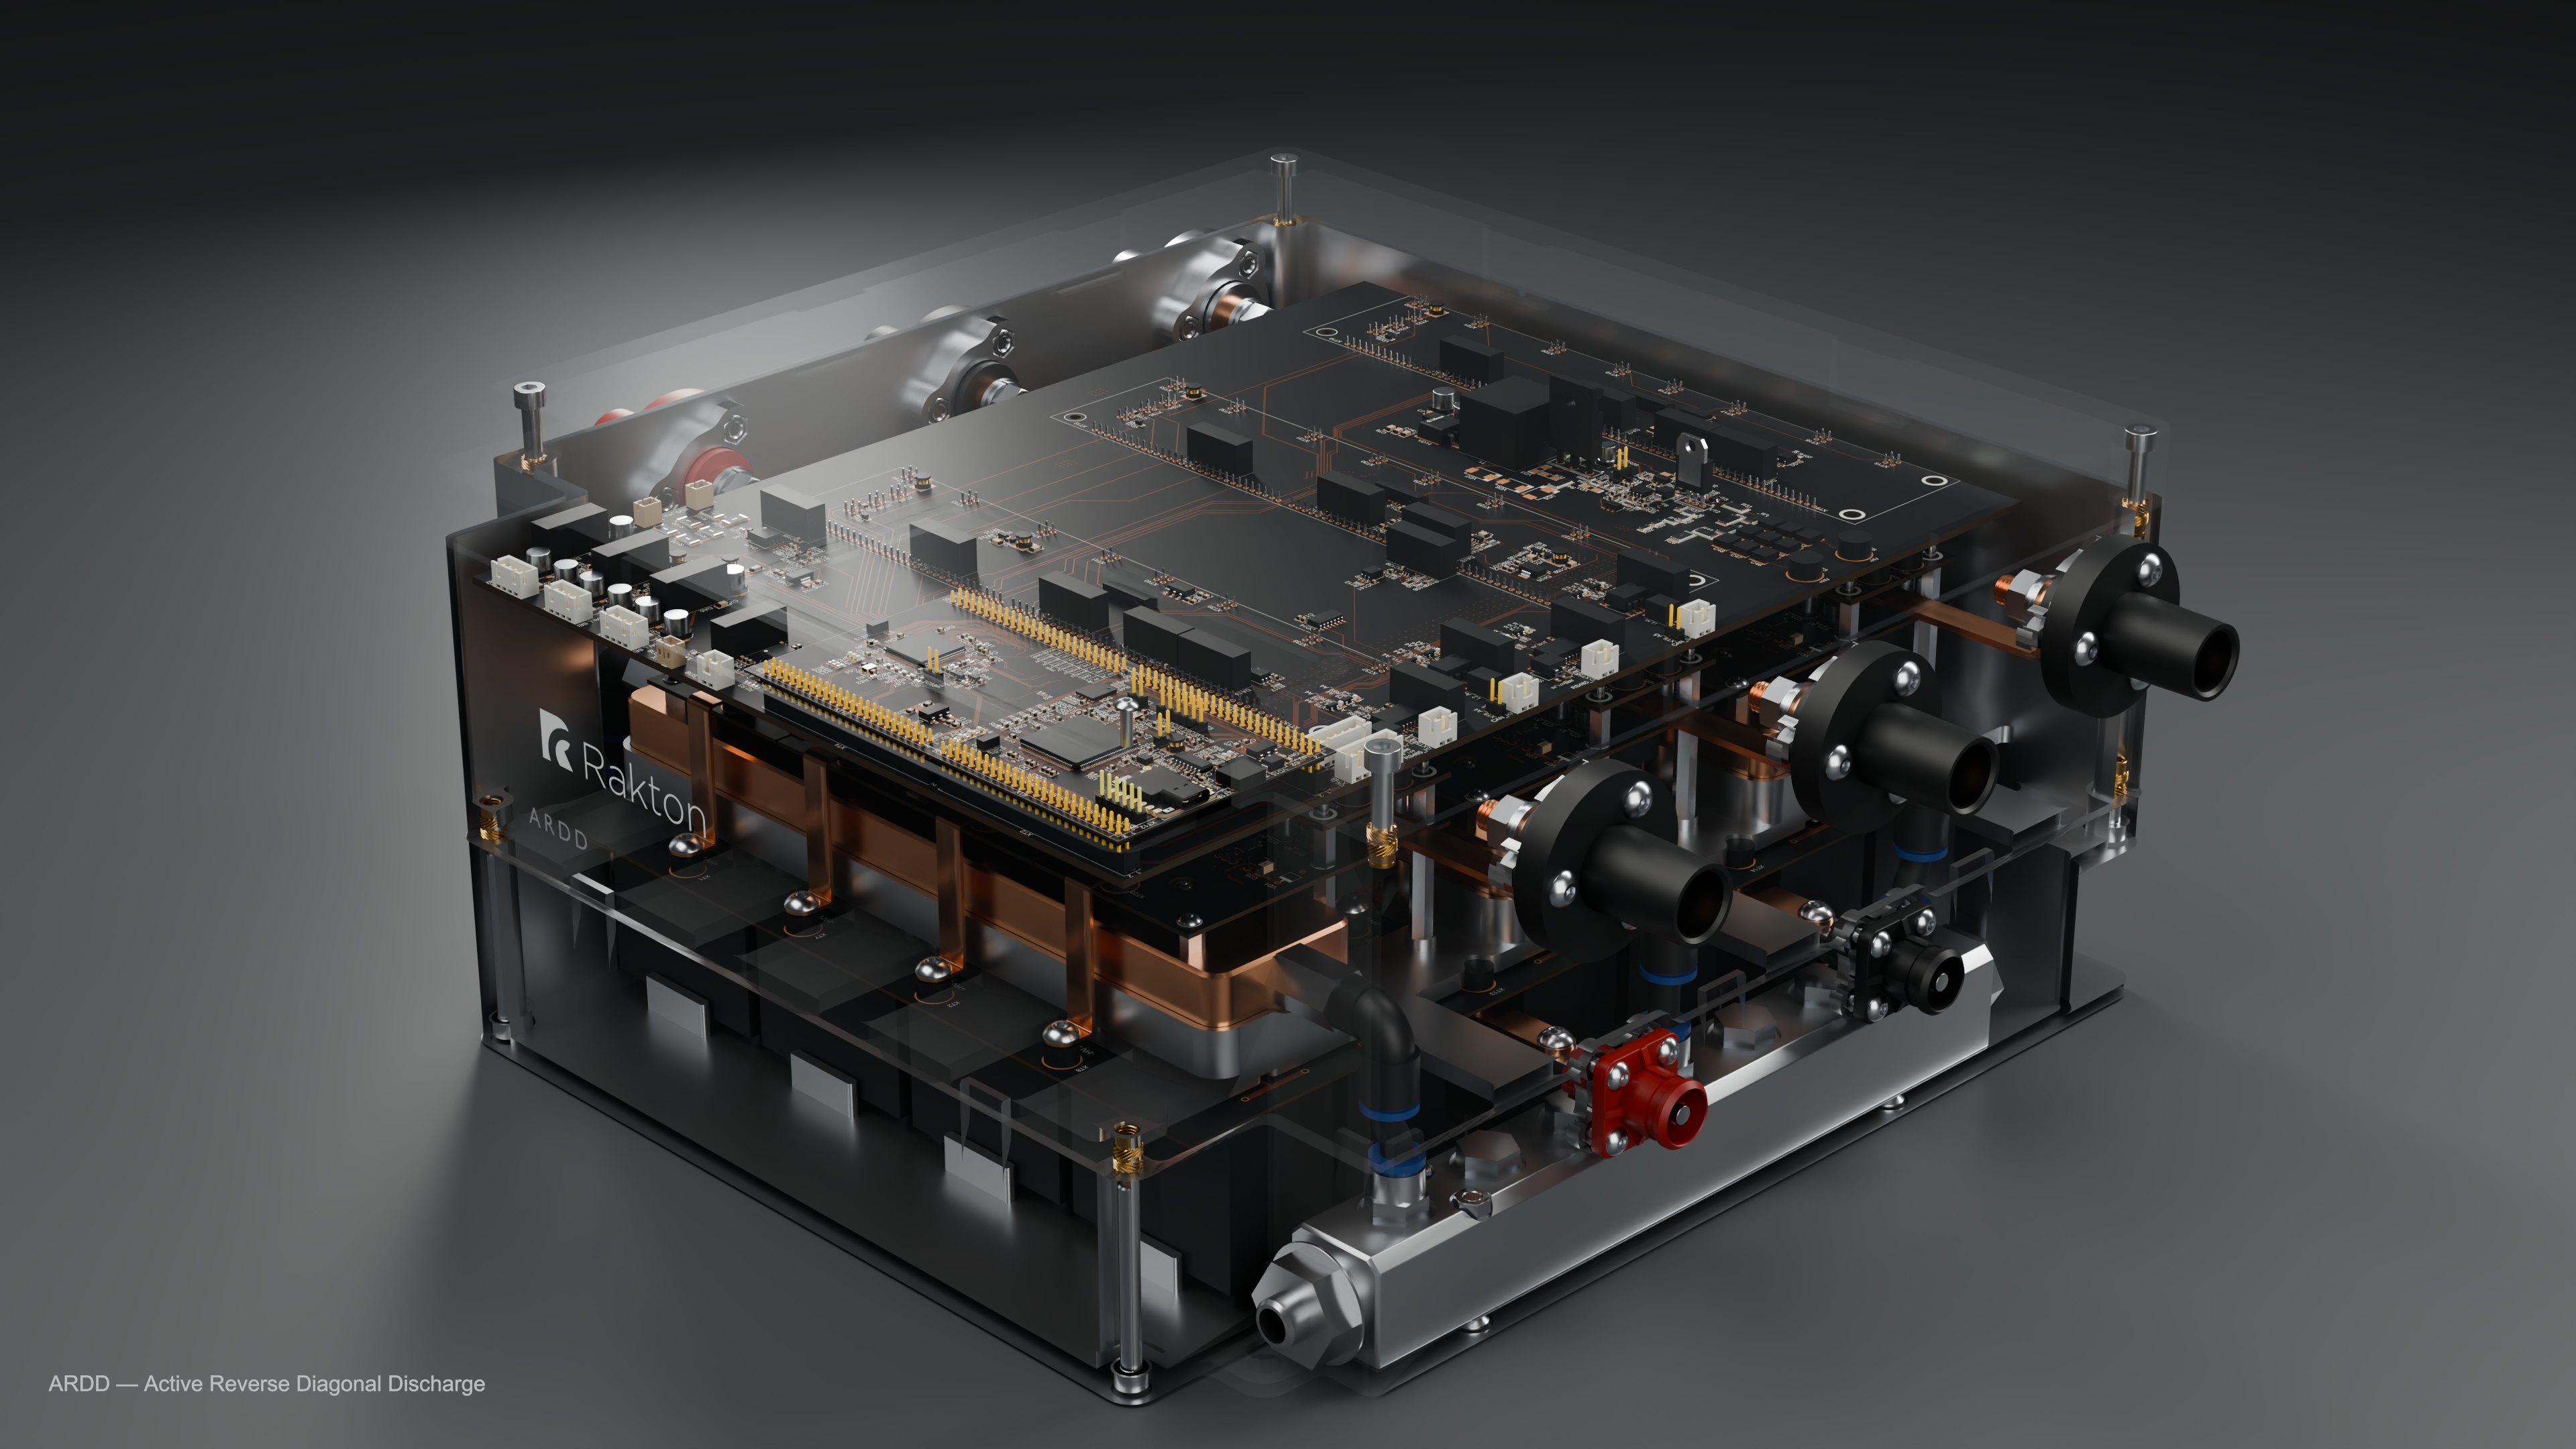
ARDD

Less heat.
More useful power.

During energy recovery, ARDD routes current through the open channels of the opposite bridge diagonal. This reduces losses and heat generation compared with diode recovery.

Phase control

Power cutoff is determined by the demagnetisation time T_demag.

Separate safeguard

Full current decay to zero is checked separately.

For your product: improved thermal balance and a longer useful power-supply window.
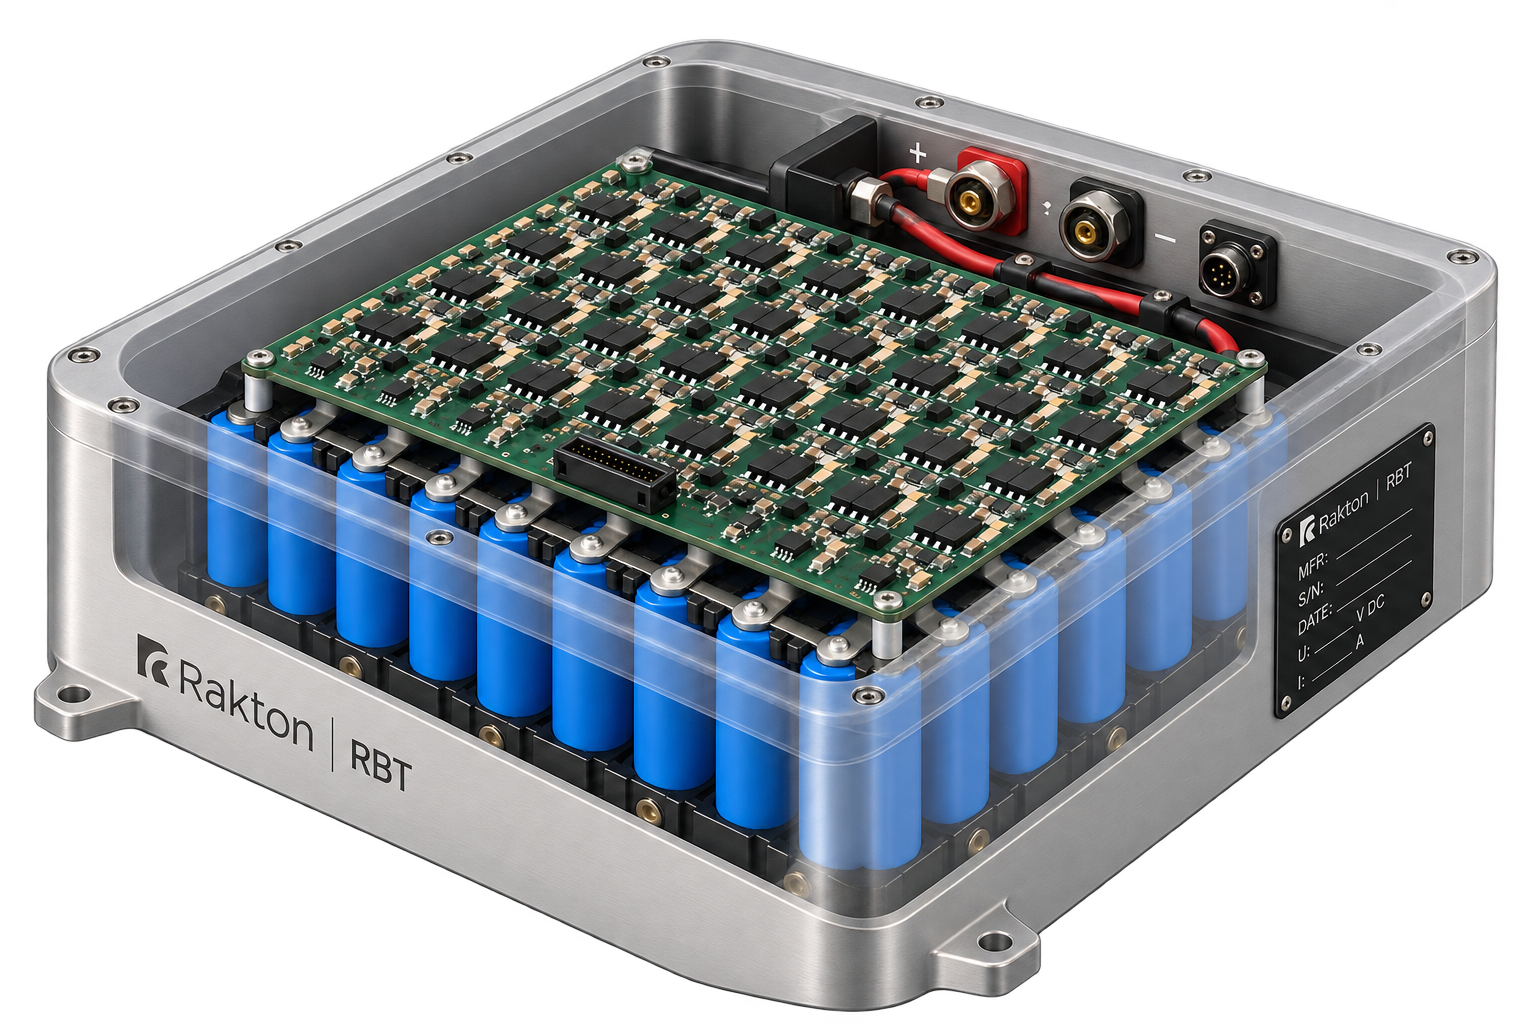
RBT

Power matched
to the operating mode.

A reconfigurable battery is an active part of the platform. Its power configuration is coordinated with the drive requirements and the product’s operating mode.

Switching electronics

Control the connection configuration of the battery modules.

Battery modules

Battery composition and parameters are defined by the end product requirements.

For your product: a power supply developed together with the electric drive system.
ARDD, comparedTwo energy-recovery paths. Device heat generation. Useful power window.Open comparison

Less heat.
More useful power.

ARDD — Active Reverse Diagonal Discharge. Phase energy returns through the open channels of the power bridge’s opposite diagonal.

Diode return path

Current flows through body diodes D3 and D2.

Q1D1Q2D2Q3D3Q4D4i > 0ABMotor phase+−DCEnergy returned to the DC link

ARDD

Current flows through the open channels of Q3 and Q2.

Q1D1Q2D2Q3D3Q4D4i > 0ABMotor phase+−DCEnergy returned to the DC link

A longer useful POWER window

Cutoff strategies compared · window lengths not to scale
Cutoff with a margin ARDD · T_demag Margin Transition Longer POWER window Up to the half-cycle boundary Zero current is checked separately

Cutoff with a margin

ARDD · cutoff based on T_demag

Additional POWER window. Full current decay is checked separately.

Heat generation in the active pair

Identical initial conditions · calculation example

Conduction losses in two devices: D2 + D3 or the open channels of Q2 + Q3.

0200400020406080100120WTime after cutoff, µsDiodes · 432 WARDD · 205.6 W
020040004080120WAfter cutoff, µsDiodes · 432 WARDD · 205.6 W

Energy converted to heat during one recovery episode

Diodes20.99 mJ
ARDD7.06 mJ

2.97× lower loss energy in this calculation

Comparison conditions

300 V · initial current 60 A · 1000 rpm · Tj = 150 °C. Includes conduction losses in two devices; switching and initial dead time are excluded.

The curves use the supplied calculation example and compare losses in the energy-return path. The separate POWER strip illustrates T_demag-based cutoff; its lengths do not specify a numerical increase in output power.

An advantage
at system level.

Your product requirements shape the entire chain: power supply, control and motion. Select what matters to your application.

RBT

Power matched to load

ARDD

Phase energy control

OW-RFMMC

Torque within the envelope

Power and torque relative to total system mass.

Motor packaging, controller parameters and battery configuration are selected together to match the end product’s loads and constraints.

Back to flight.

Torque, mass and thermal balance contribute to the reason the aircraft exists: range and operating duration.

For products
that demand more.

Range. Flight duration. Mass.

Passenger and commercial drones: high torque under mass constraints, energy control and a coordinated power supply.

Discuss an aviation application

Engineering
behind the technology.

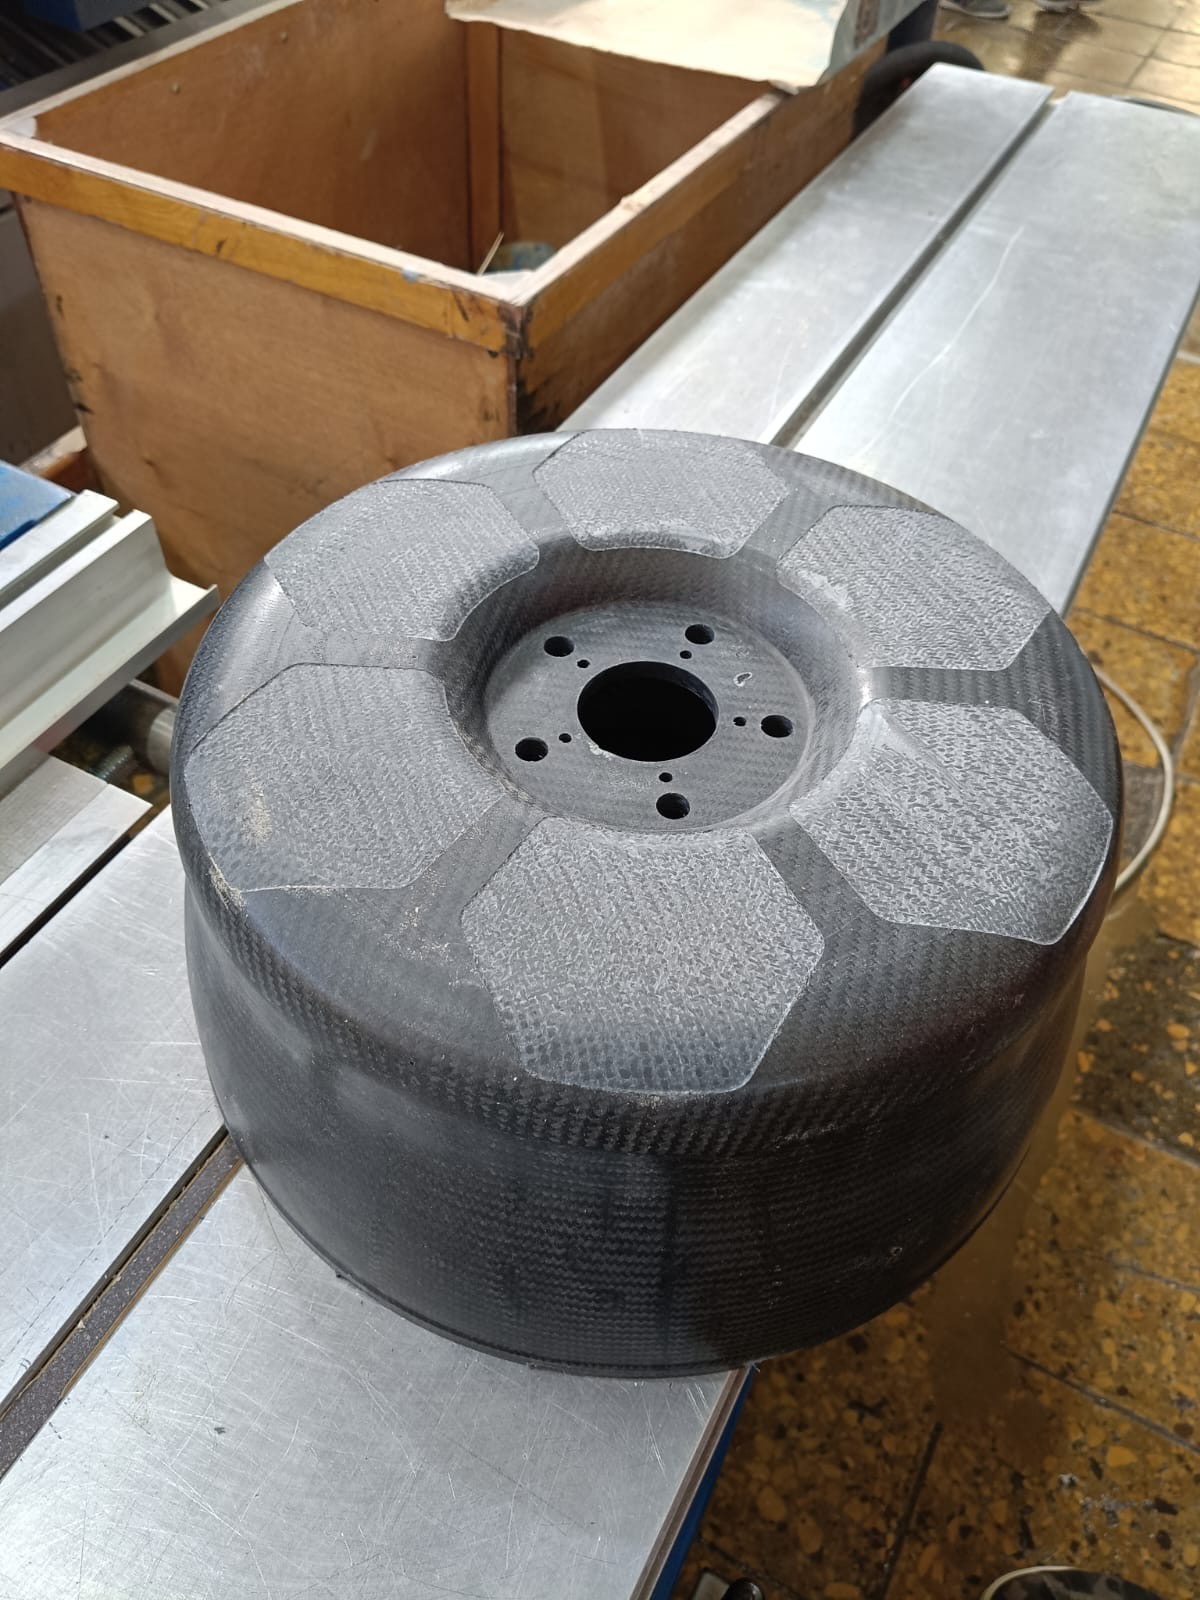
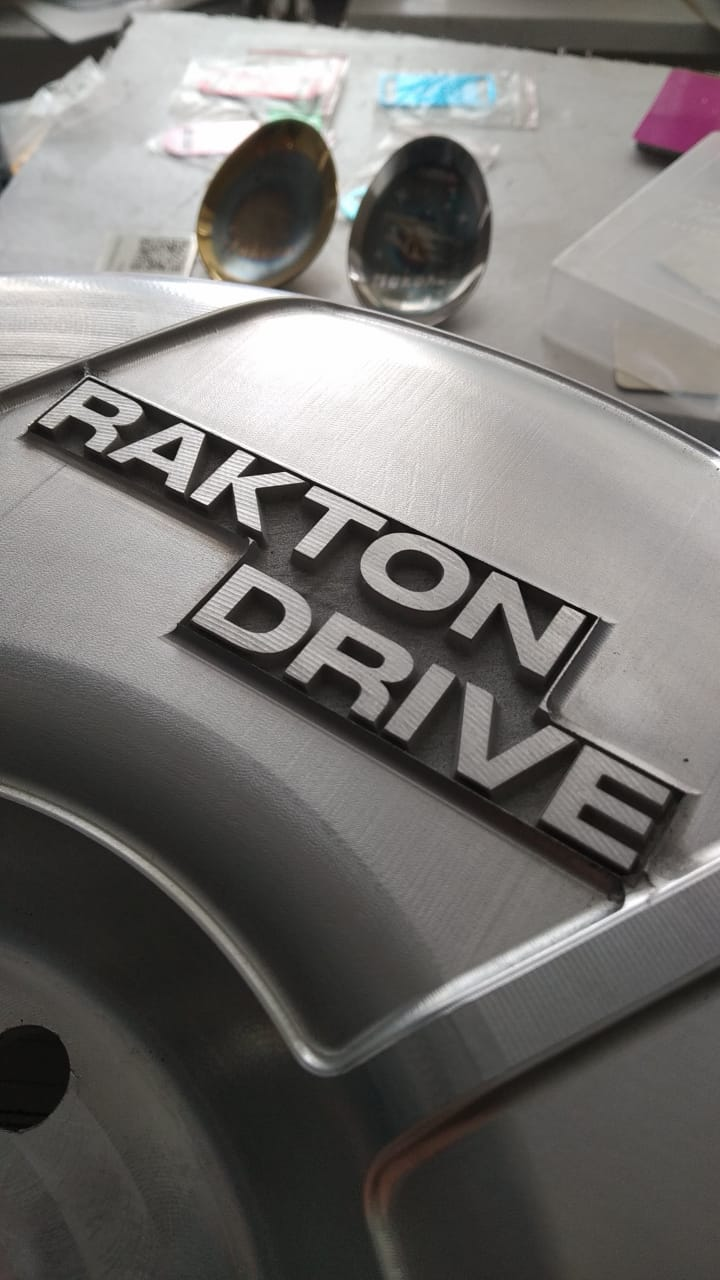
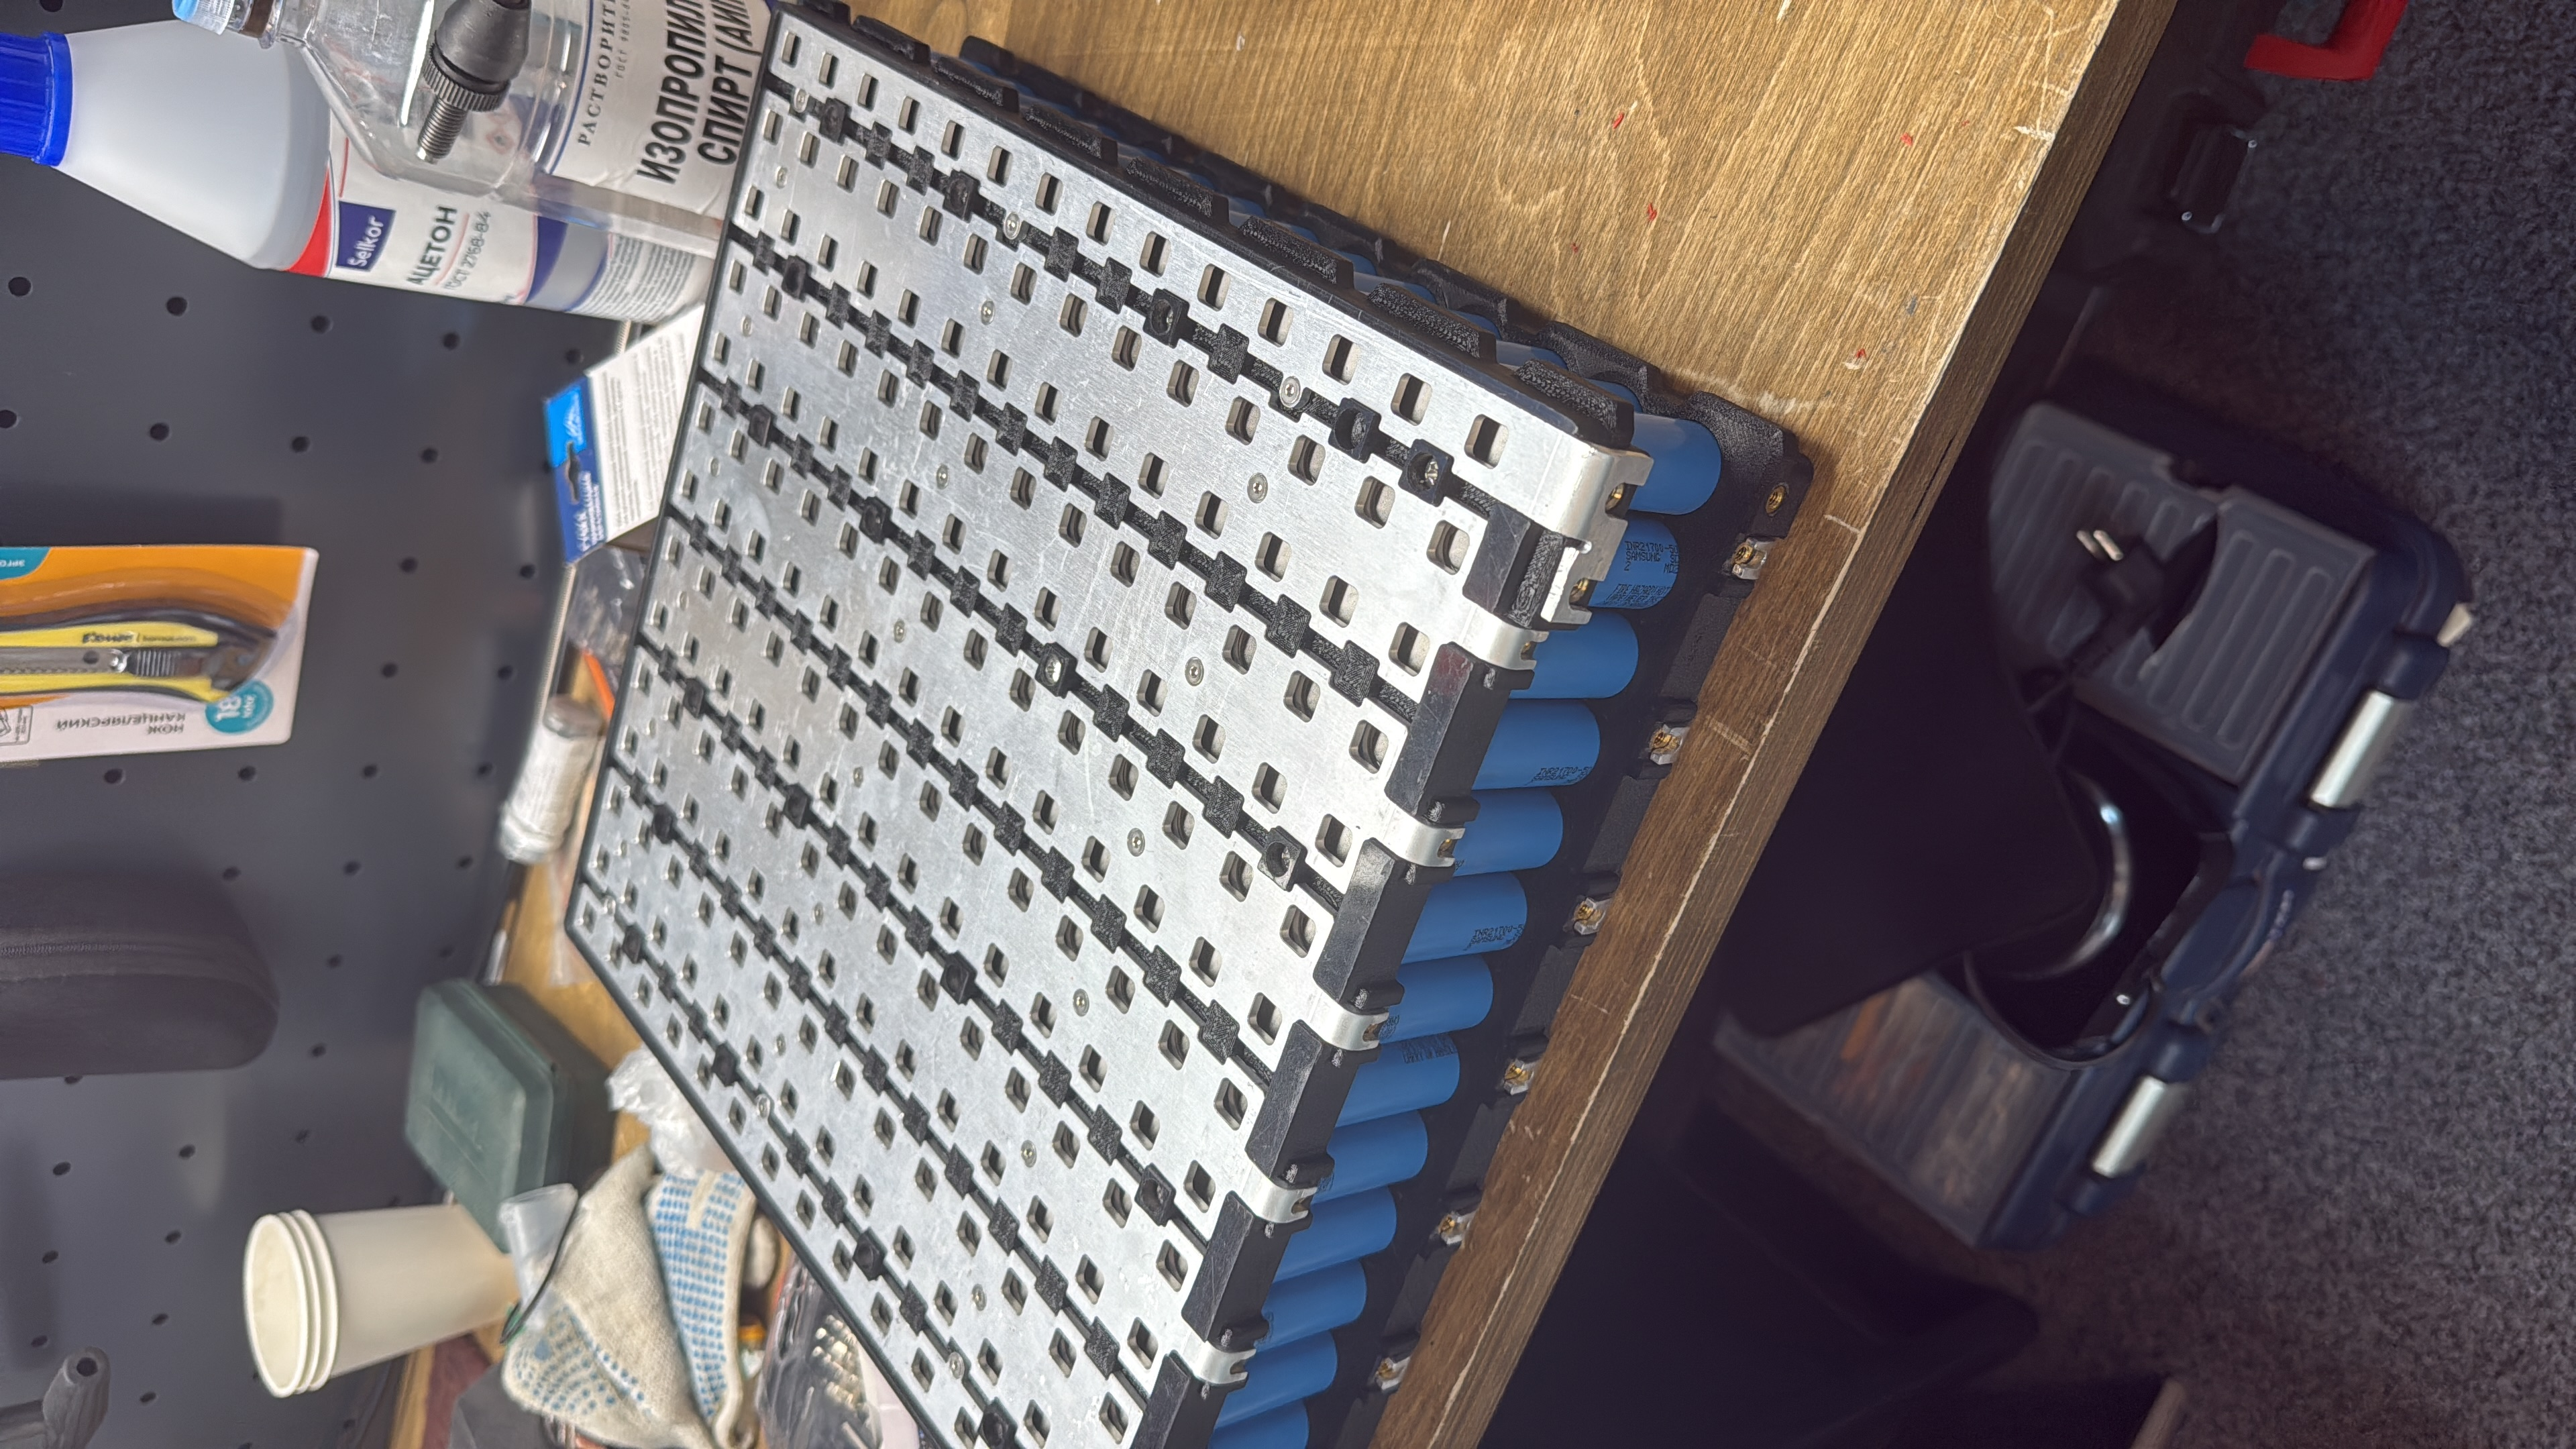
Project materials: manufactured parts, machining and battery assemblies. The technical discussion starts with your requirements.

Composite shell · project photograph
Metal cover · machining
Battery assembly · project photograph

Start with your requirements.

A complete platform, a component, custom development and manufacturing, technology licensing or integration support. You can also start with a question.

RaktonDrive@gmail.com

Your email app will open. You confirm sending.